EvolveNav: Proactive Preflection and Self-Evolving Memory for Zero-Shot Object Goal Navigation
Submitted to ACM Multimedia (ACM MM), 2026
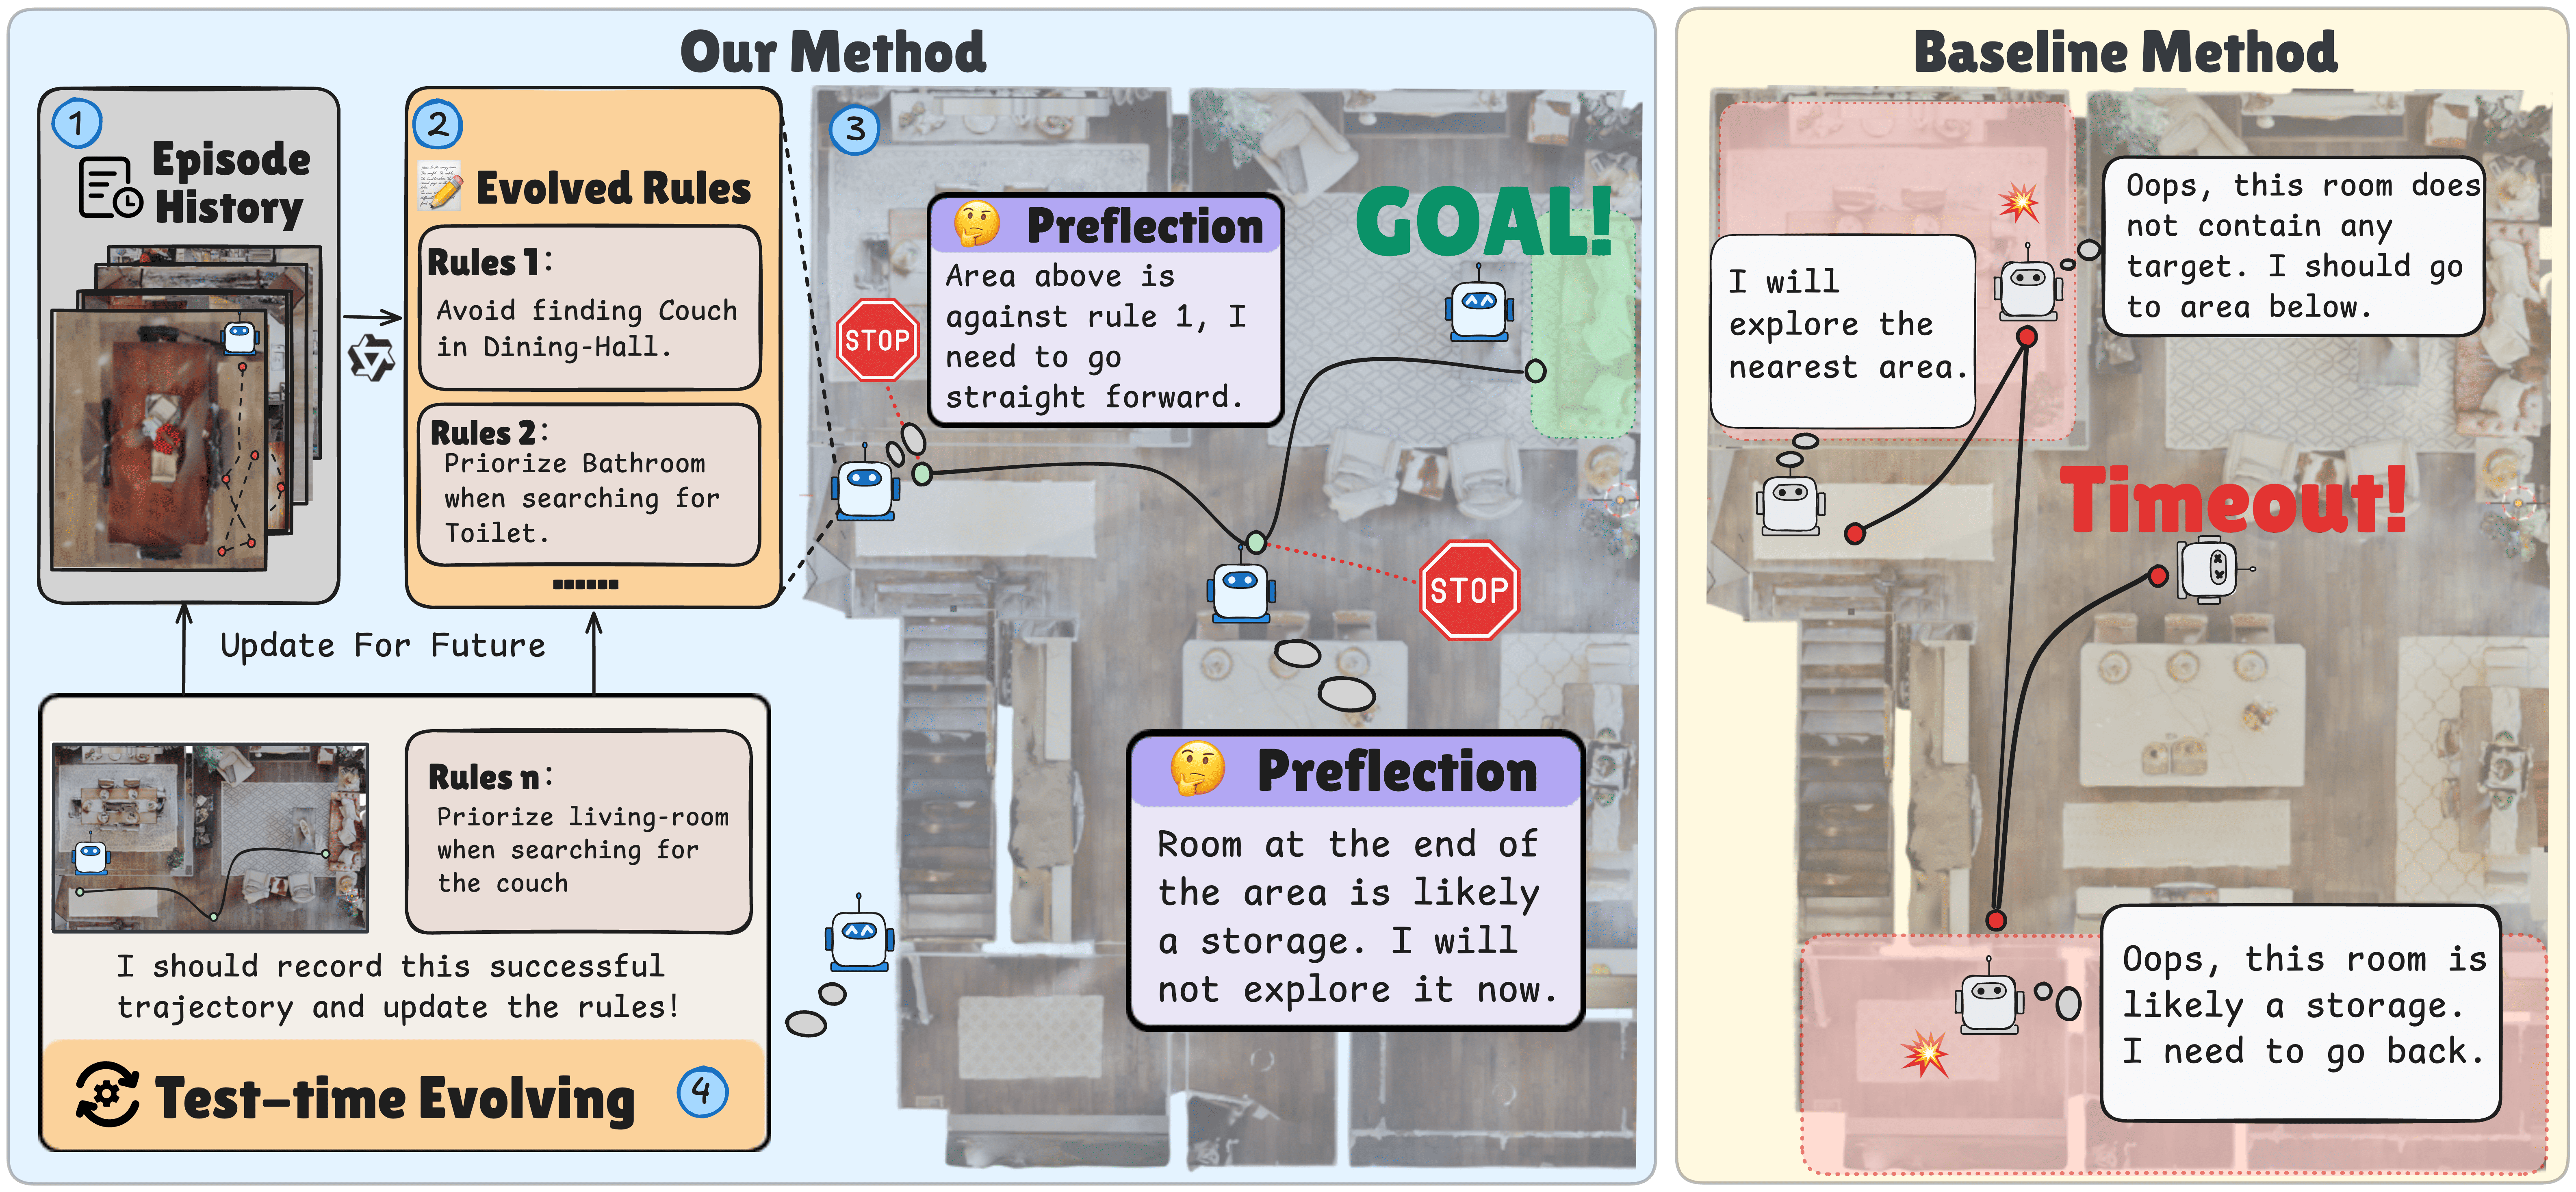
EvolveNav remembers what happened during earlier navigation attempts and uses those lessons before choosing the next direction.
Abstract
EvolveNav studies zero-shot object-goal navigation with an agent that can improve during deployment. It extracts rules from past trajectories, weighs their usefulness, and uses memory-guided preflection to consider likely outcomes before moving. The public preprint reports improved success rates and fewer unnecessary steps against zero-shot baselines.